🤖 Robot Data Is the IROS Theme
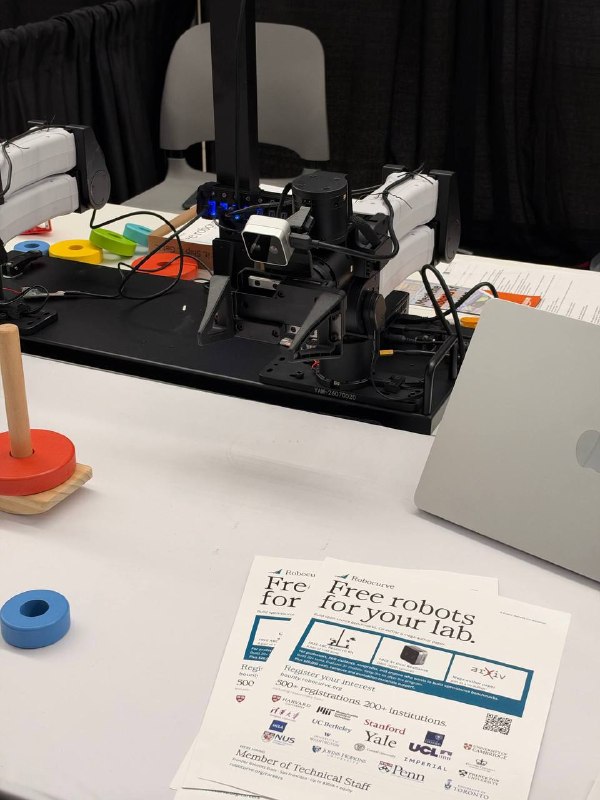
At IROS 2026, 8 dedicated sessions focus on VLA models, which turn an image and text instruction into robot actions. Force and tactile sensing also appear throughout because cameras alone are not enough for dexterous work.
Diffusion and flow matching now generate robot movements, not images. Humanoid work covers walking and whole-body control, while one competition had robots assembled IKEA furniture themselves.
Reinforcement learning and imitation learning appear in almost every second paper. Robots can already do a lot, but data remains the bottleneck. Unlike language models, they are only starting to build a training pool.
📊@tech
Post #3965
3.7K



- ❤ 601
- 👍 187
- 🙏 123
- 👏 104
- 🎉 73
- 🔥 1